Chi-Pin Huang
Research Scientist

f11942097[at]ntu.edu.tw
I am a Research Scientist at NVIDIA Research, working on Embodied AI.
My research focuses on reasoning-enhanced vision-language-action models that enable robots to reason about tasks and environments and translate that reasoning into effective actions in the physical world.
Before joining NVIDIA as a Research Scientist, I received my Ph.D. from National Taiwan University (NTU) in January 2026, advised by Prof. Yu-Chiang Frank Wang. I also earned my bachelor’s degree in Computer Science and Information Engineering (CSIE) from NTU in 2022 and worked as an Applied Scientist Intern at Microsoft, developing deep learning models for Bing Maps.
News
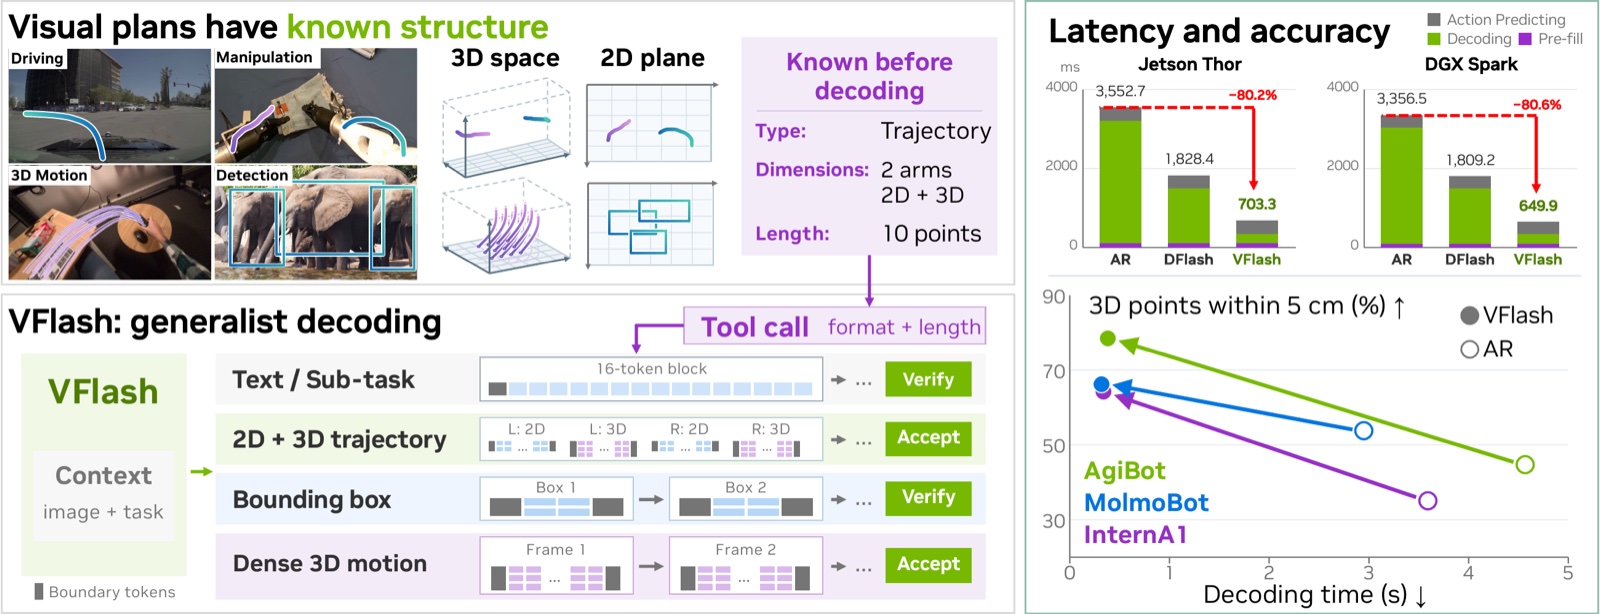
| Nov 06, 2026 | Our new preprint VFlash is now available on arXiv. |
|---|---|
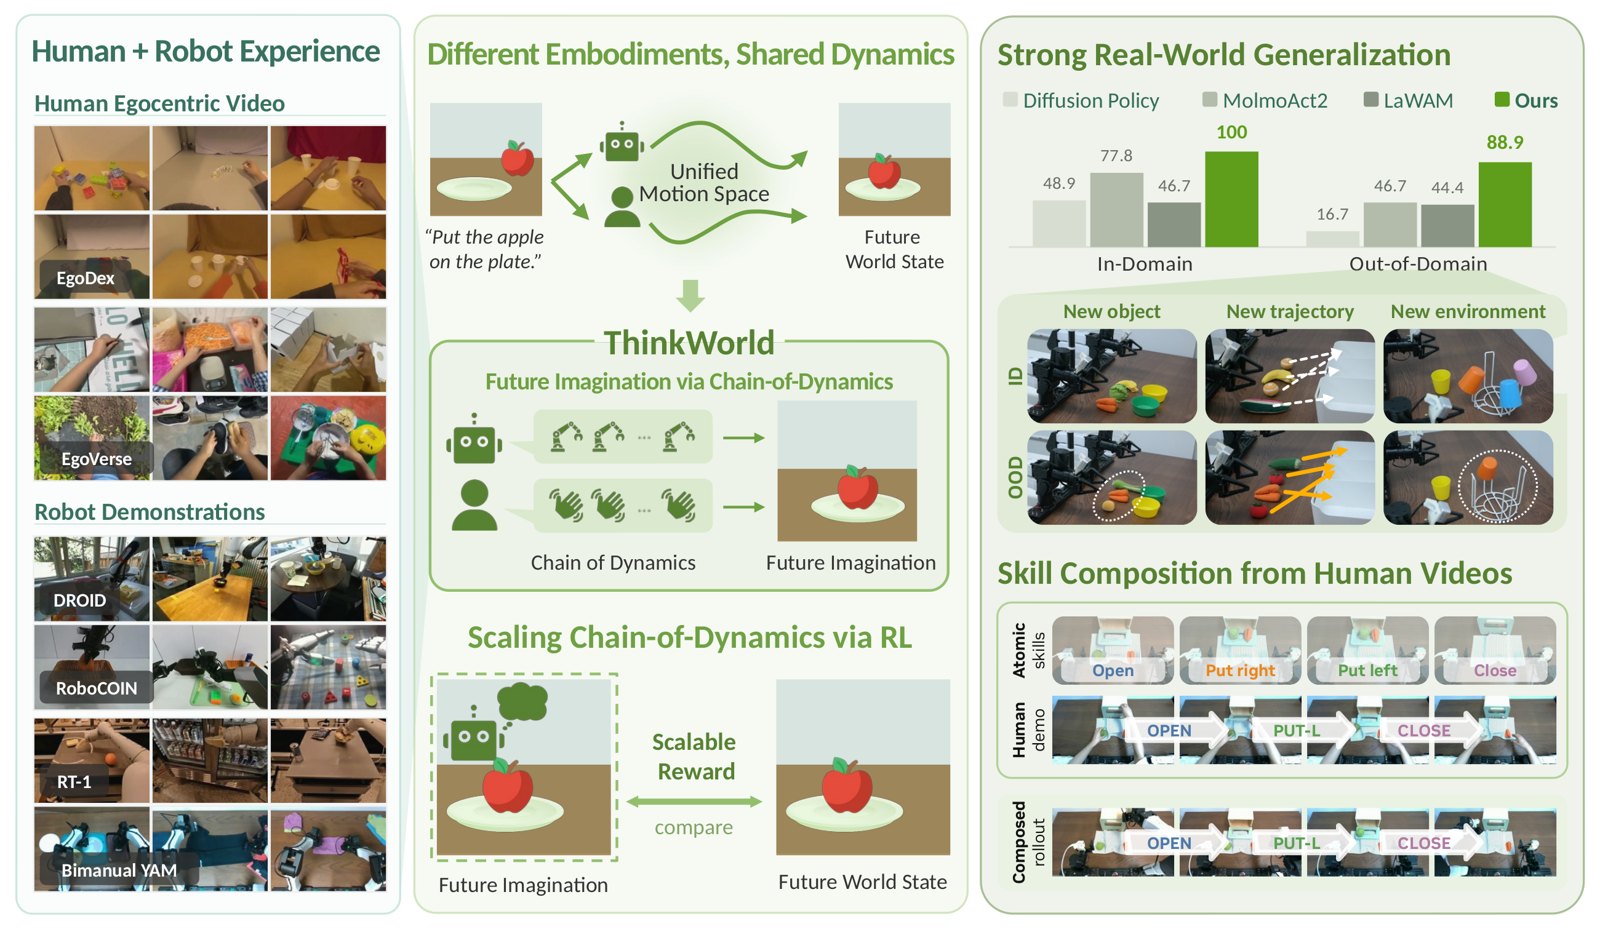
| Oct 28, 2026 | Our new preprint ThinkWorld is now available on arXiv. |
| Oct 20, 2026 | Our paper PhysCaP is accepted at the 8th Robot Learning Workshop @ NeurIPS 2026 and the Workshop on Agentic Robotics @ CoRL 2026. |
| Feb 20, 2026 | Our paper Fast-ThinkAct is accepted at CVPR 2026. |
| Jan 10, 2026 | Received my Ph.D. from National Taiwan University (NTU) and will be joining NVIDIA Research as a Research Scientist. |
| Dec 28, 2025 | Our papers SANTA and TA-Prompting are accepted at WACV 2026. |
| Sep 19, 2025 | Our paper ThinkAct is accepted at NeurIPS 2025. |
| Jun 26, 2025 | Our paper Continual Personalization for Diffusion Models is accepted at ICCV 2025, and MotionMatcher is accepted at the ICCV 2025 Workshop on P13N: Personalization in Generative AI. |
| Feb 27, 2025 | Our paper VideoMage is accepted at CVPR 2025. |
| Feb 03, 2025 | Joined NVIDIA Research as a Research Intern. |
| Jul 02, 2024 | Our papers Receler and Select and Distill are accepted at ECCV 2024. |
| Jan 16, 2024 | Our paper RAPPER is accepted at ICLR 2024. |
Featured Publications
- arXiv 2611
- NeurIPSW 2026
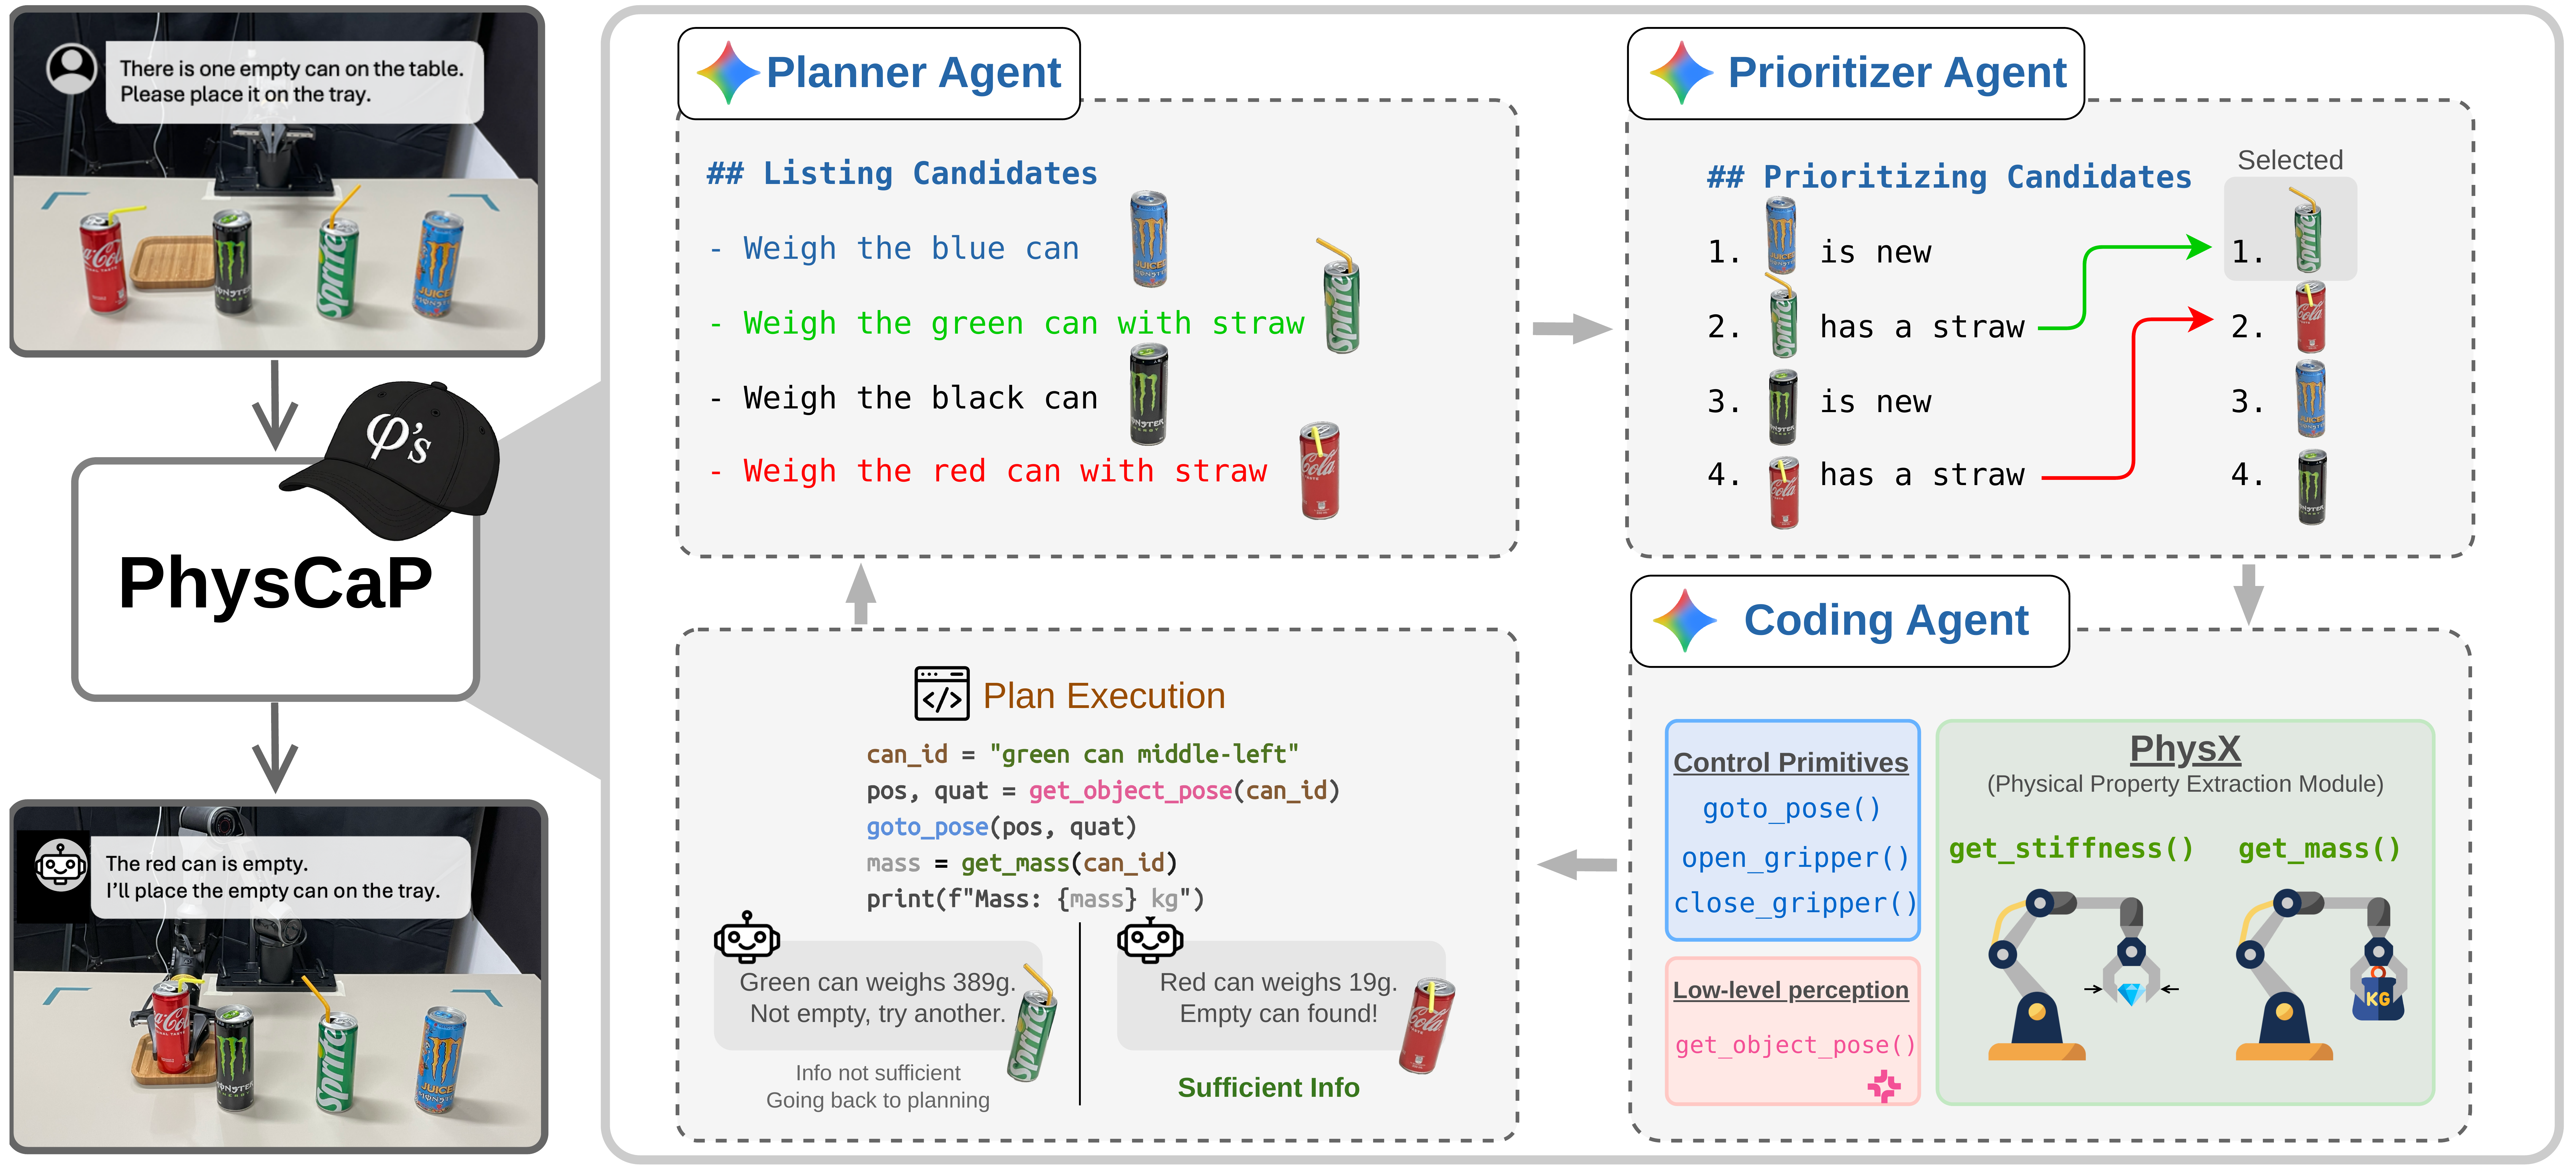 PhysCaP: Grounding Code-as-Policy Agent with Physics-Informed Exploration
Guides robots to actively probe hidden physical properties, such as mass and stiffness, for manipulation when vision alone is insufficient.
NeurIPS 2026 Workshop on Robot Learning; CoRL 2026 Workshop on Agentic Robotics, 2026 - CVPR 2026
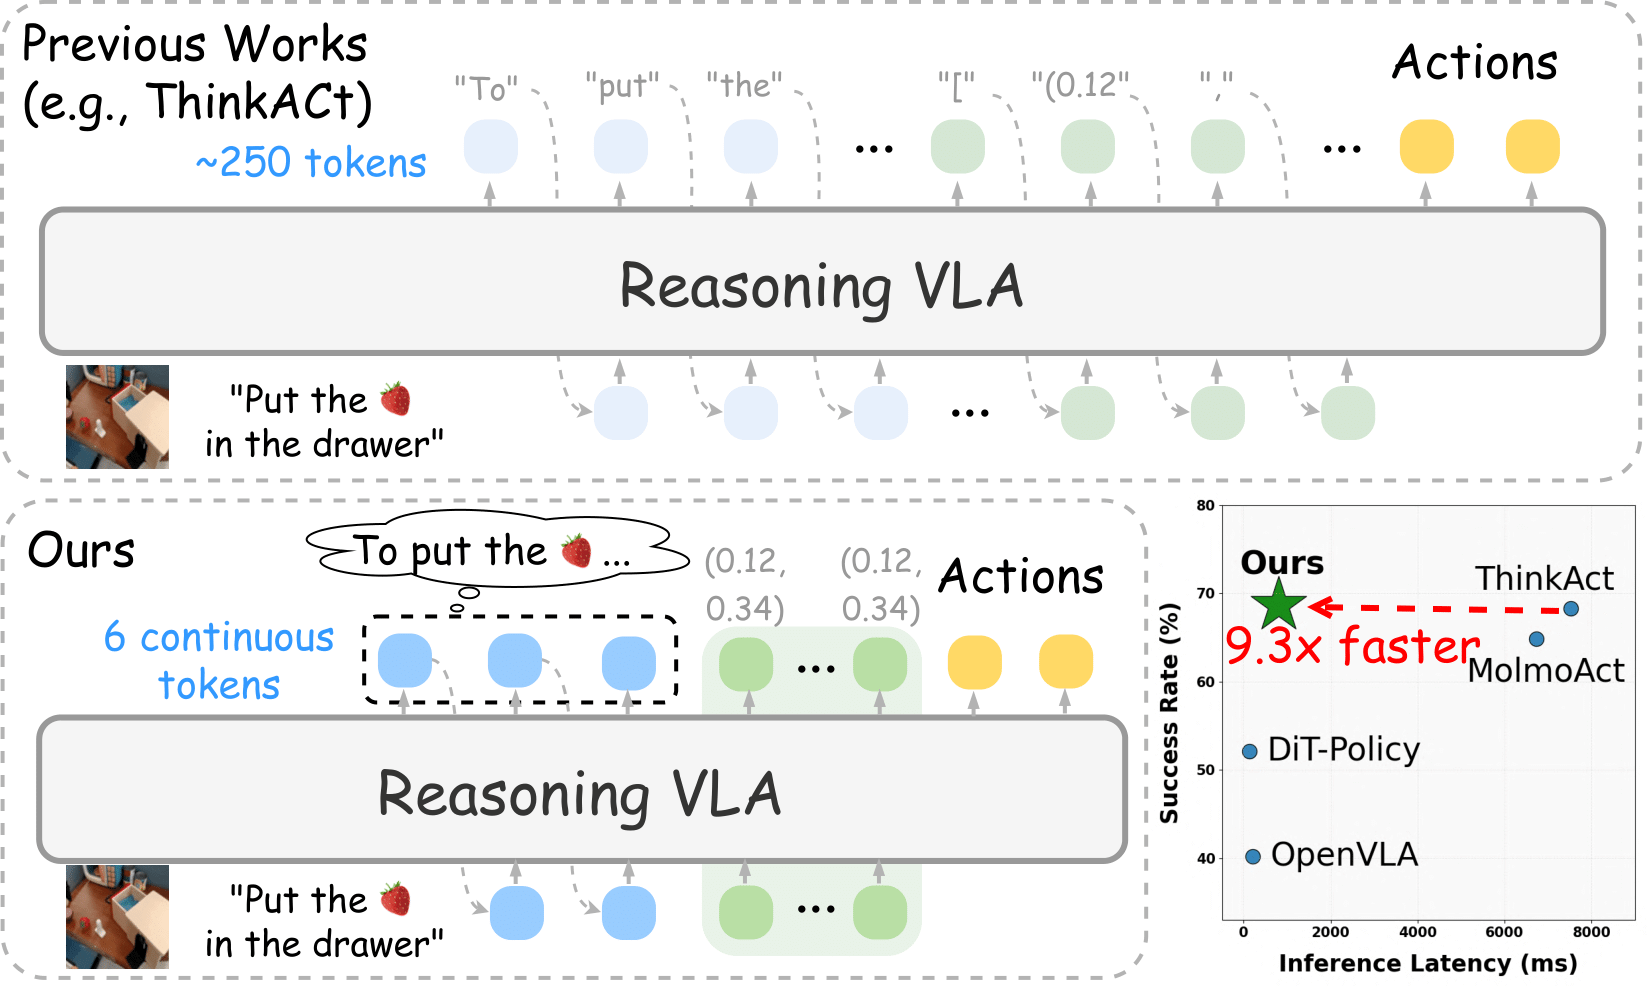 Fast-ThinkAct: Efficient Vision-Language-Action Reasoning via Verbalizable Latent Planning
Compresses textual reasoning into compact, verbalizable latent plans for faster vision-language-action inference.
In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026 - NeurIPS 2025
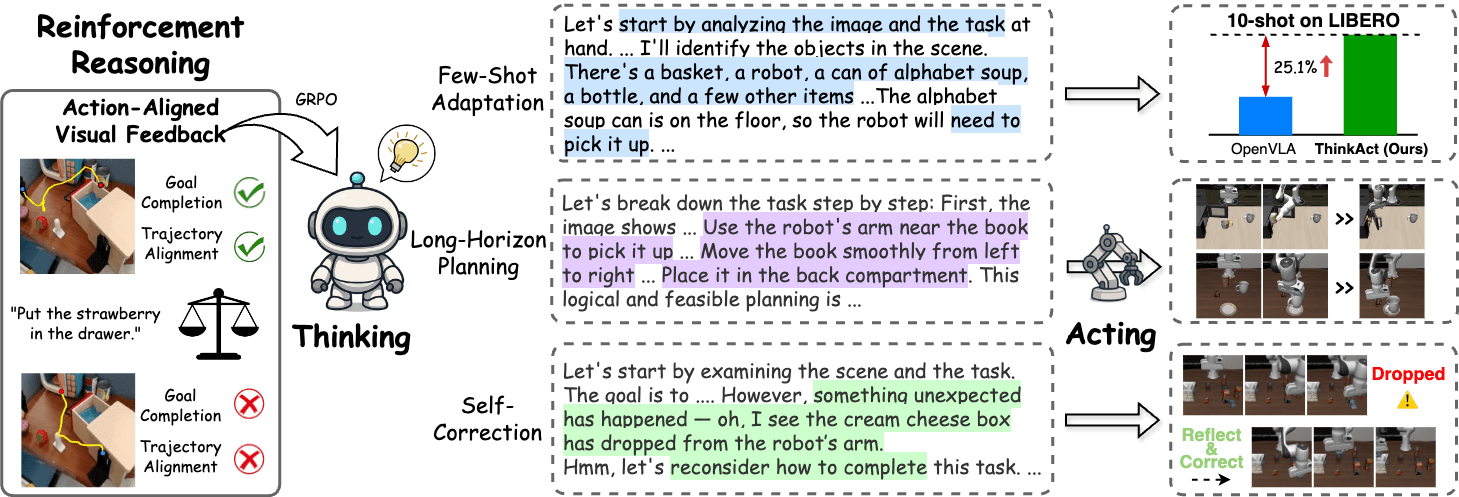 ThinkAct: Vision-Language-Action Reasoning via Reinforced Visual Latent Planning
Connects embodied reasoning to robot actions through reinforced visual latent planning, supporting long-horizon tasks and self-correction.
Advances in Neural Information Processing systems (NeurIPS), 2025 - CVPR 2025
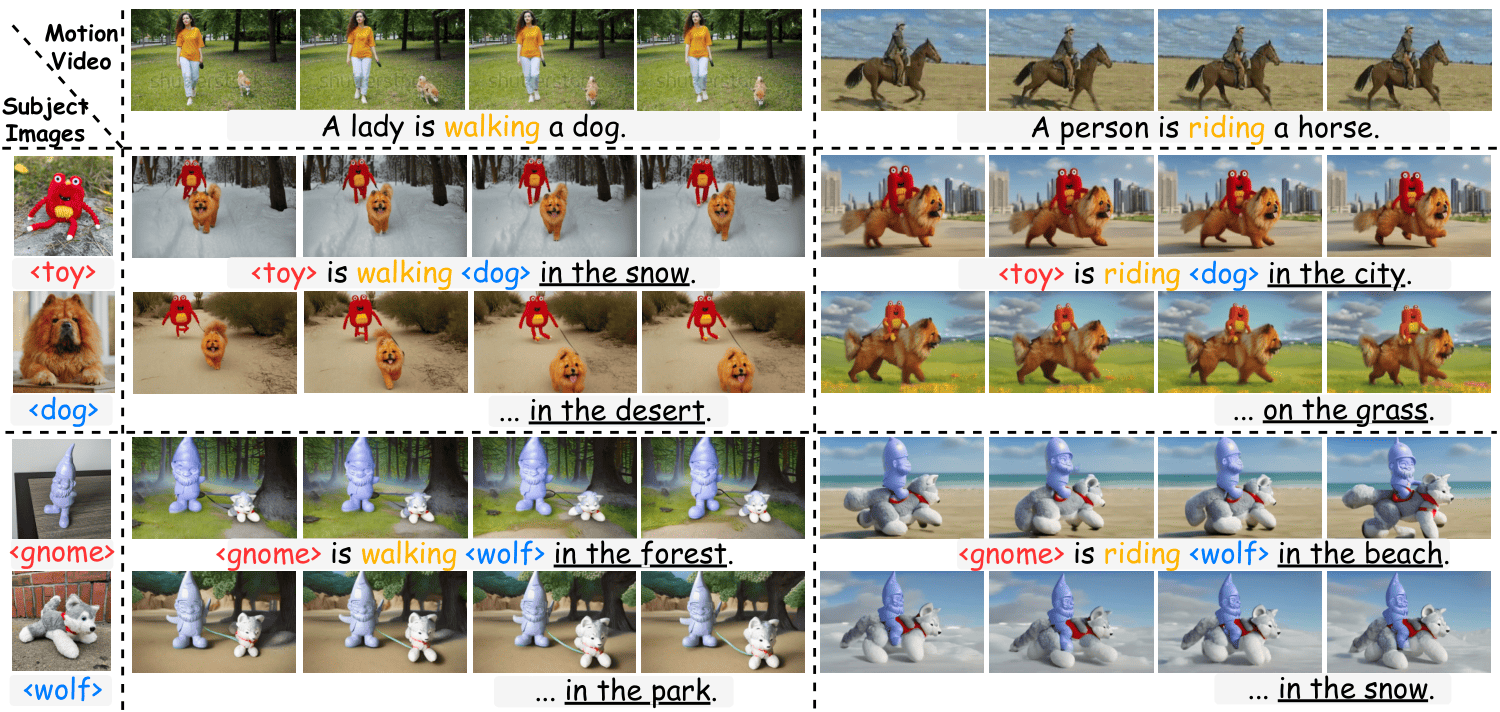 VideoMage: Multi-Subject and Motion Customization of Text-to-Video Diffusion Models
Combines multiple subject identities and reference motions to generate customized videos with consistent appearances and interactions.
In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2025 - ECCV 2024
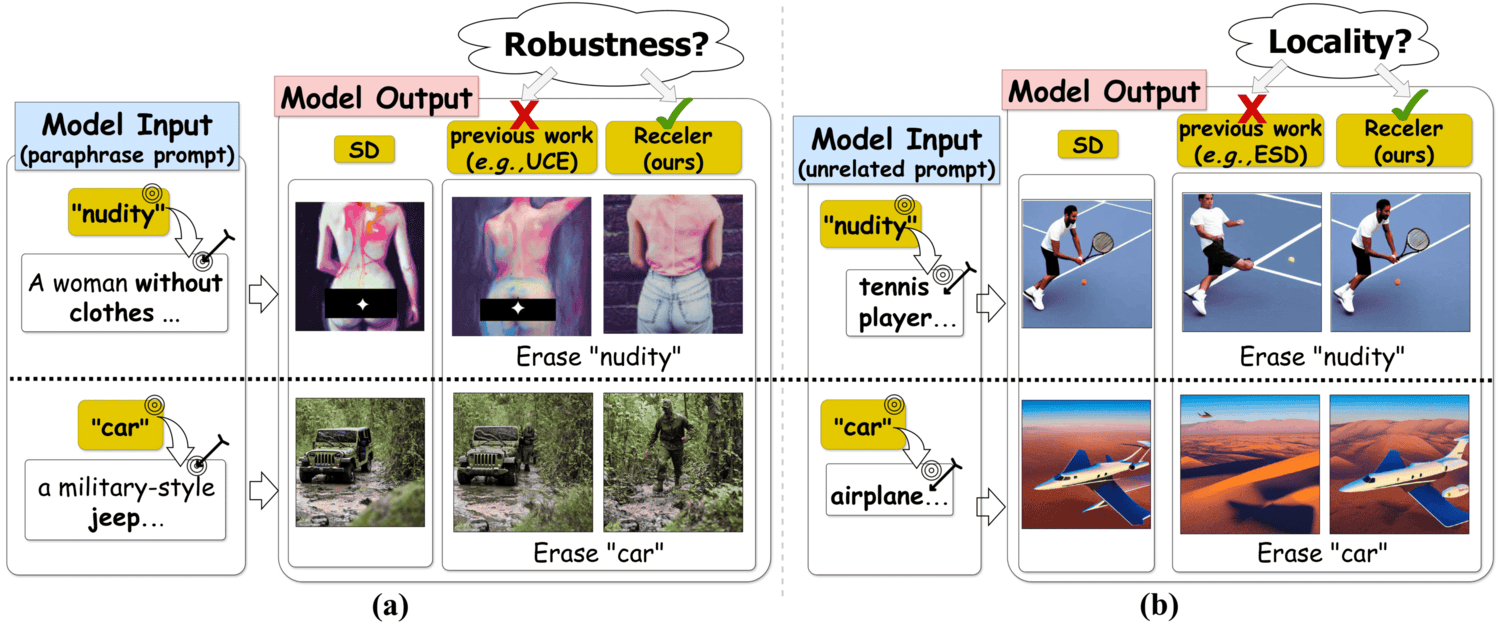 Receler: Reliable concept erasing of text-to-image diffusion models via lightweight erasers
Uses lightweight erasers to suppress target concepts in diffusion models while preserving unrelated concepts and resisting adversarial prompts.
In European Conference on Computer Vision (ECCV), 2024